Matrix Structural Analysis (Introduction) - Theory & Concepts
Learning Objectives
- Understand the fundamentals of Matrix Structural Analysis.
- Formulate stiffness matrices for truss and beam elements.
- Perform coordinate transformations.
- Assemble global stiffness matrices and apply boundary conditions.
Matrix Structural Analysis is the foundation of all modern structural analysis software. It provides a systematic method for analyzing complex structures (trusses, beams, frames, grids) by formulating the equilibrium equations in matrix form.
Stiffness Method
Also known as the Displacement Method. It is preferred for computer implementation because the procedure is the same regardless of the degree of indeterminacy.
Global Stiffness Equation
The fundamental equation of the stiffness method.
Global Stiffness Equation
The fundamental equation of the stiffness method.
Variables
| Symbol | Description | Unit |
|---|---|---|
| Global Stiffness Matrix (System Property) | - | |
| Global Displacement Vector (Unknowns) | - | |
| Global Force Vector (Applied Loads) | - |
Stiffness sensitivity visual
This figure asks a different question from matrix assembly: how does the relative stiffness change the displacement and the share of force carried by each member?
Stiffness sensitivity and force partition
The relative stiffnesses control the middle displacement and split the reaction and member-force magnitudes in the ratio k1 to k2.
Procedure
The process of Matrix Structural Analysis involves building the mathematical model of the structure piece by piece, then solving it simultaneously.
General Method
- Discretize the Structure: Identify nodes (joints) and elements (members). Number them systematically.
- Define Degrees of Freedom (DOF): Identify unknown displacements (translations and rotations) at each node.
- Form Element Stiffness Matrices (): Calculate the stiffness matrix for each member in its local coordinate system.
- Transformation: Transform element stiffness matrices from local to global coordinates using rotation matrices ().
Coordinate Transformation
Transforms element stiffness matrices from local to global coordinates.
Global Matrix Assembly
- Assemble Global Stiffness Matrix (): Add terms from element stiffness matrices into the corresponding positions in the global matrix based on node connectivity.
- Apply Boundary Conditions: Reduce the matrix by removing rows/columns corresponding to zero displacements (supports).
- Solve for Displacements (): Invert and multiply by .
Global Displacement Solution
Solves for unknown global displacements.
Local Force Recovery
- Calculate Member Forces (Local Force Recovery): Once the global nodal displacements () are found, the internal end forces () for each individual member (like shear, moment, and axial force) must be calculated in its own local coordinate system. This is done by extracting the relevant global displacements for that specific member (), multiplying by the local stiffness matrix (), and adding any fixed-end forces () caused by loads applied directly along the member span.
Local Force Recovery Equation
Calculates the internal end forces for each individual member.
Variables
| Symbol | Description | Unit |
|---|---|---|
| Internal end forces for the member | - | |
| Local stiffness matrix of the member | - | |
| Global displacements extracted for the specific member | - | |
| Fixed-end forces caused by applied loads | - |
Member-force recovery visual
The solved global displacement is restricted to each member's local displacement vector before the signed member force is recovered.
Recovering member forces from displacement
Member 1 uses u1 and u2, while Member 2 uses u2 and u3; their local relations recover signed axial forces.
Stiffness Matrices for Truss and Beam Elements
Truss Element (2D)
A truss member has 2 degrees of freedom (DOF) at each node (horizontal , vertical ). Total 4 DOF per element.
Truss Element Stiffness Matrix
The local stiffness matrix for a 2D truss member.
Variables
| Symbol | Description | Unit |
|---|---|---|
| - | ||
| - |
Beam Element (2D)
A beam member has 2 DOF at each node (vertical , rotation ). Total 4 DOF per element (neglecting axial deformation).
Beam Element Stiffness Matrix
The local stiffness matrix for a 2D beam member.
Variables
| Symbol | Description | Unit |
|---|---|---|
| Length of the beam element | - | |
| Modulus of elasticity | - | |
| Moment of inertia | - |
Global vs. Local Coordinate Systems
In matrix analysis, members are oriented in various directions. Therefore, equations written for a single member must be transformed into a common, structure-wide coordinate system before they can be assembled.
Coordinate Transformation
- Local Coordinates (): Aligned with the axis of each individual member. The local axis runs along the length of the member, and is perpendicular to it. The local stiffness matrix relates forces and displacements purely within this local frame.
- Global Coordinates (): The overarching fixed coordinate system applied to the entire structure.
- Transformation Matrix (): A matrix containing the direction cosines (cosine and sine of the angle between the local and global axes) of the member. It is used to convert the local stiffness matrix into the global stiffness matrix for that member.
The relationship for transformation is:
This ensures that when member matrices are added together at a common node, they are summing forces acting in the exact same global directions.
Coordinate mapping visual
Before member contributions can share a global system, local axes and stiffness quantities must be mapped with direction cosines.
Local-to-global coordinate mapping
With dᴸ = T dᴳ, the transformation maps global displacement components into member-local coordinates, and kᴳ = Tᵀ kᴸ T maps local stiffness into the common global system.
Assembly of Global Stiffness Matrix
The assembly process is crucial. Each element connects two nodes (e.g., node and node ). The terms in the element stiffness matrix corresponding to node are added to the global matrix locations for node , and similarly for node and the cross-terms ().
Direct-stiffness coefficient reference
This fixed visual answers a different question from the existing step-through assembly simulation: where each global coefficient comes from, which degree of freedom remains free, and how the restrained rows recover reactions. It is not a second assembly sequence.
Direct-stiffness coefficient provenance and boundary reduction
Connectivity identifies the source of global matrix terms, highlights the shared k1 plus k2 diagonal, and reduces the restrained system to the free equation for u2.
Two complementary simulations
The existing simulation walks through the four-step matrix assembly sequence. The companion sensitivity simulation below keeps the same small model but varies k1, k2, and P to connect the assembled matrix to displacement, reactions, and member forces.
Node 2 displacement 0.0625 metres. support reaction R1 -11.25 kilonewtons. support reaction R3 -18.75 kilonewtons. member force N1 +11.25 kilonewtons. member force N2 -18.75 kilonewtons. equilibrium residual 0.00e+0 kilonewtons.
Fixed supports enforce . Arrow direction follows the selected sign convention; geometry is not to scale.
Assembled global matrix
The middle diagonal receives both member contributions.
| K | u₁ | u₂ | u₃ |
|---|---|---|---|
| F1 | 180 | -180 | 0 |
| F2 | -180 | 480 | -300 |
| F3 | 0 | -300 | 300 |
Matrix entries: kN/m
Boundary reduction and solution
The restrained degrees of freedom are removed from the solve, but the full matrix still recovers the support reactions. Positive member force means tension in the member's local left-to-right direction.
Response and force recovery
Force partition by relative stiffness
For a nonzero load, the reaction magnitudes partition as and . Change one stiffness to see the share move.
At , all forces are zero even though the stiffness shares remain visible as a sensitivity ratio.
Node Numbering and Matrix Bandwidth
How you choose to number the nodes in your structure drastically affects the computational efficiency of solving the matrix equations.
- Bandwidth: The non-zero elements in a global stiffness matrix tend to cluster around the main diagonal. The "bandwidth" is the maximum distance from the main diagonal to a non-zero element.
- Efficiency: Solving large systems of equations is faster and requires less computer memory if the bandwidth is small.
- Optimal Numbering Rule: To minimize bandwidth, nodes should be numbered such that the maximum numerical difference between any two connected nodes in the entire structure is kept as small as possible. For example, numbering nodes across the short dimension of a rectangular grid is much better than numbering them along the long dimension.
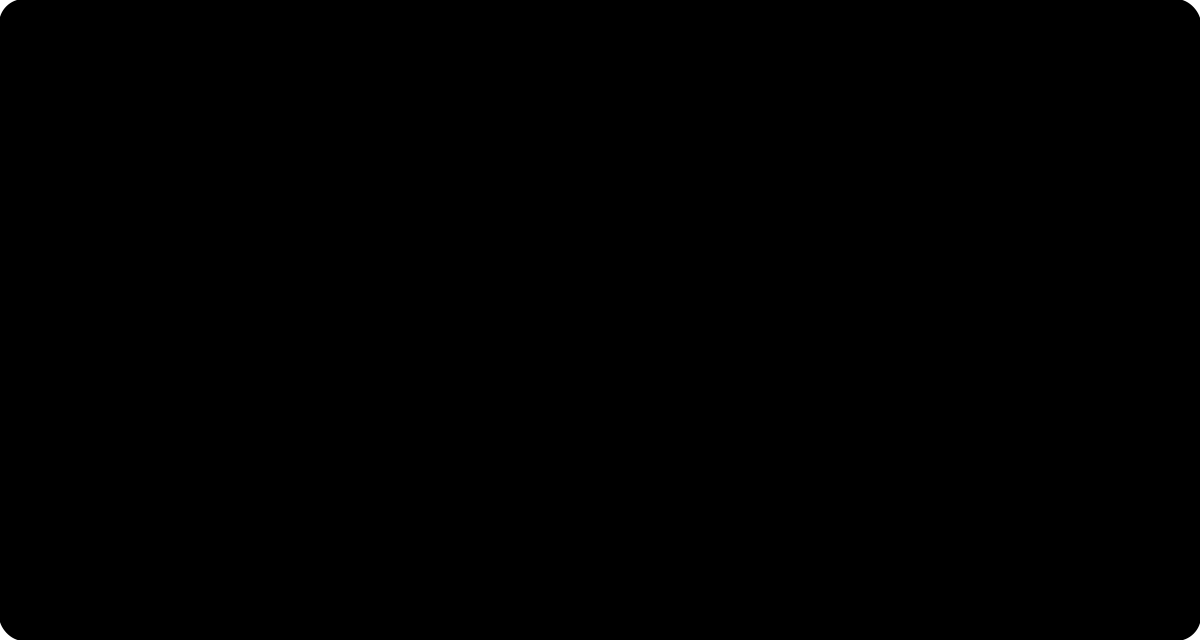
Bandwidth visual
The node-ordering choice is a computational question: it changes the distance of nonzero matrix entries from the diagonal without changing the structure.
Node numbering and matrix bandwidth
The two matrices represent the same five-node chain with rows and columns permuted together. Natural ordering has half-bandwidth 2, while the illustrated permutation has half-bandwidth 4; connectivity and stiffness physics are unchanged.
Application of Boundary Conditions
Before the global equilibrium equations () can be solved, boundary conditions (known displacements at supports) must be applied. Otherwise, the global stiffness matrix is singular (non-invertible) because the structure is free to move as a rigid body.
Methods for Boundary Conditions
- Partitioning Method: The global matrices are partitioned into known and unknown displacements and forces. The equations corresponding to known zero displacements are mathematically eliminated or separated, resulting in a reduced, invertible stiffness matrix.
- Penalty Method: A very large stiffness value (e.g., ) is added to the diagonal element of the global stiffness matrix corresponding to the restrained degree of freedom, effectively enforcing a zero displacement without altering the size of the matrix.
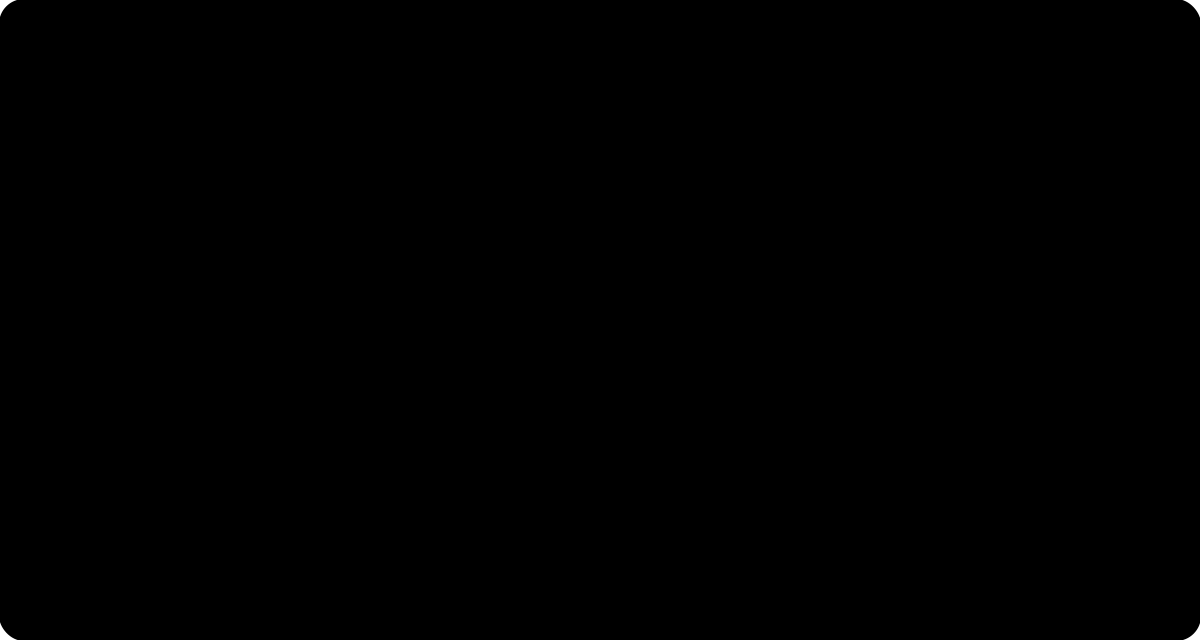
Equilibrium check visual
The restrained rows of the full global system recover reactions, which should close the applied-load balance after the free displacement is solved.
Reaction recovery and equilibrium residual
For the shown positive rightward load, both restrained reactions are negative in the global sign convention. The recovered reactions satisfy R1 plus P plus R3 equals zero, while the free-row residual is zero.
- Stiffness Method solves for unknown displacements.
- Degrees of Freedom (DOF): Independent displacements (translations/rotations) that define the deformed shape.
- Matrix Analysis is systematic and scalable, ideal for computer software.
- Assembly: Combining element stiffness matrices into a global matrix based on connectivity.
- Transformation: Rotating local element coordinates to align with the global system.
- Node Numbering: Proper node numbering minimizes matrix bandwidth, leading to faster computational solution times and lower memory usage.